Senior Robotics Engineer · Boston, MA

Tyler Johnson

I build the software that makes industrial robots move: motion planning, manipulation, control, and the interfaces that let the outside world drive them. Currently building Locus Array, a new class of fully autonomous fulfillment robots, at Locus Robotics.

  • Motion Planning
  • Manipulation
  • Control
  • Robot OS
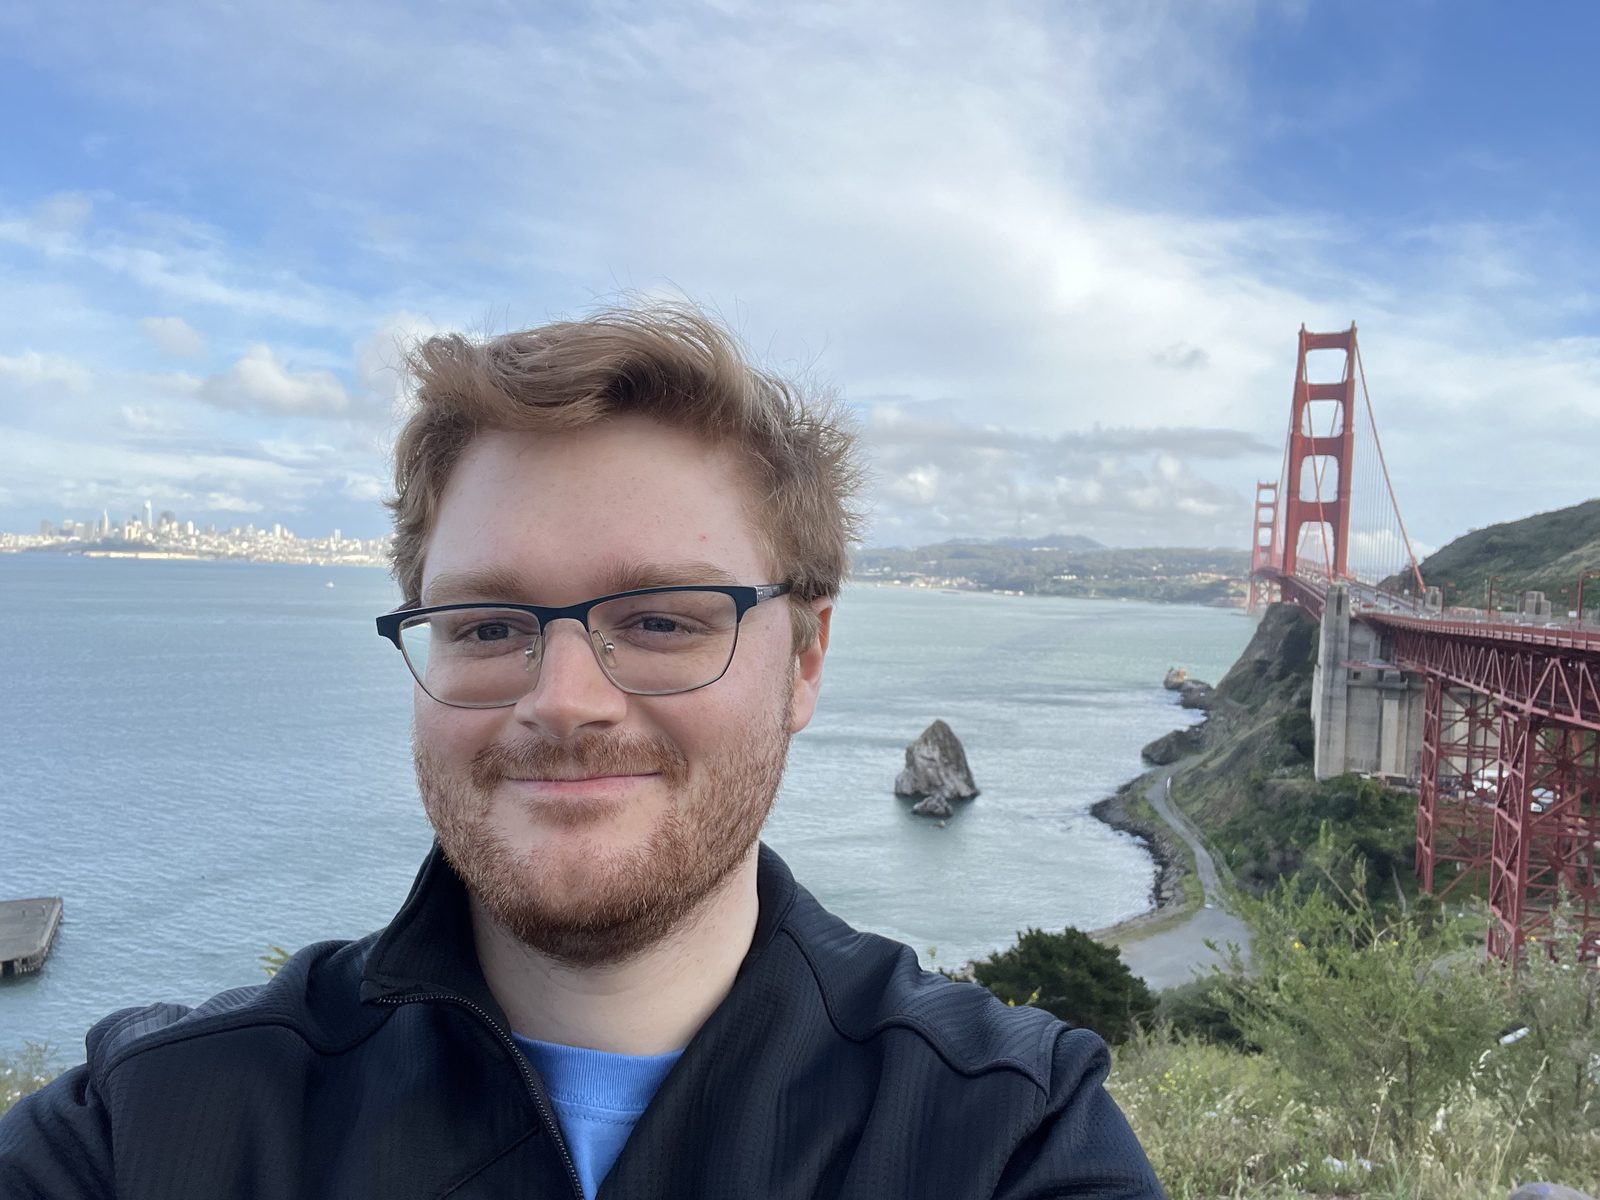
Tyler in front of the Golden Gate Bridge, with San Francisco across the bay
Golden Gate Bridge, San Francisco
01 / About

About

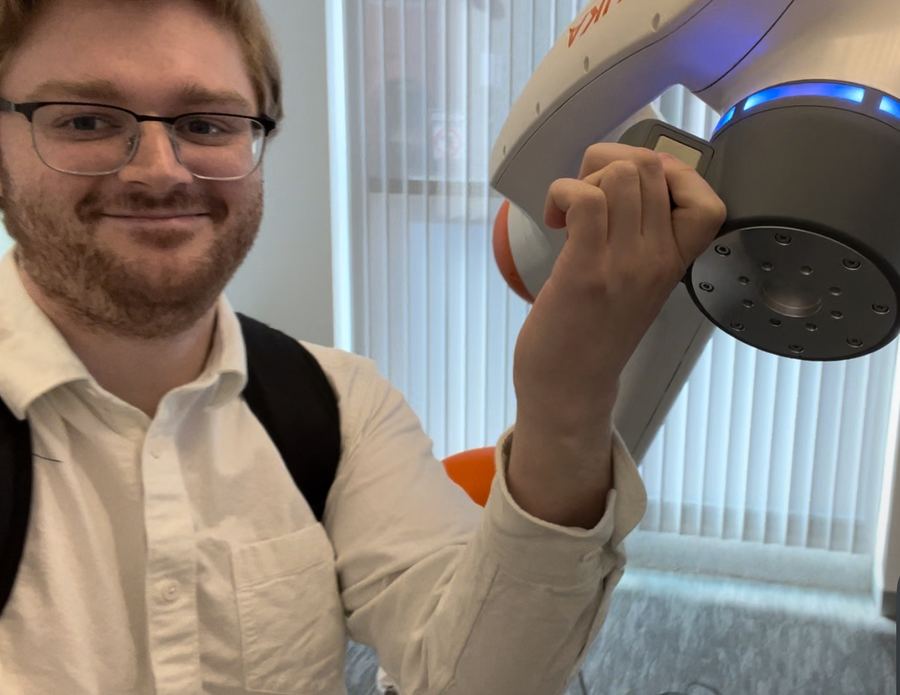
Tyler hand-guiding a KUKA LBR collaborative robot arm
Hand-guiding a KUKA LBR

I'm a robotics software engineer focused on kinematics, motion planning, control, and the real-time interfaces that expose a robot to the world.

I've worked across industrial robotics at Kawasaki, KUKA, and now Locus Robotics, building everything from core robot OS modules to the tooling and applications that ship on top of them.

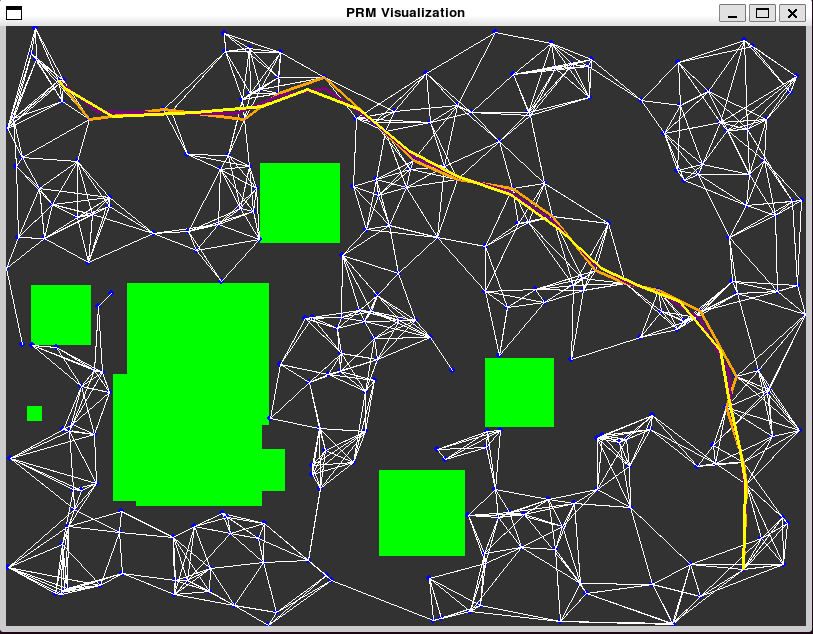
My favorite problems are in motion: solvers that respect torque and acceleration limits while staying smooth, planners that thread constrained spaces, and control interfaces that make the robot easy to drive.

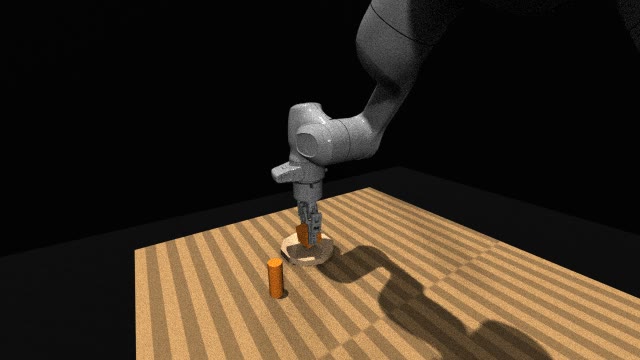
Outside of work I prototype constantly: motion planning playgrounds, drones, VLA test benches. I stay deep in the open-source stack: ROS 2, Gazebo, Drake, and whatever simulator is fastest this year.

MS ECE
Carnegie Mellon University — computer vision, AI, robotics, security
BS ECE
University of Florida — computer engineering, hardware through software
02 / Experience

Experience

  1. Locus Robotics

    Senior Robotics Engineer Current

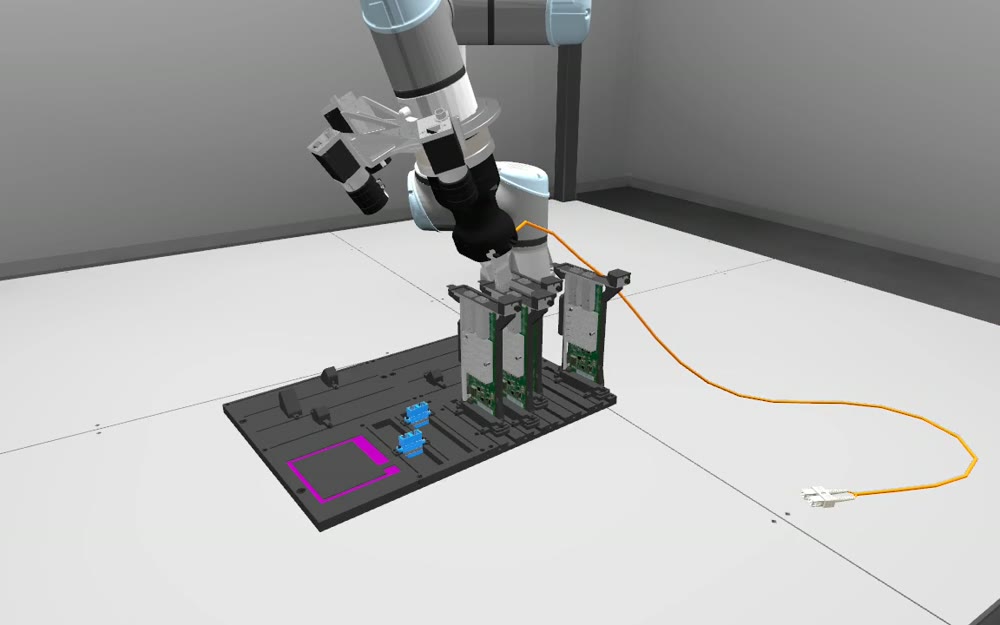
    I develop the software that runs the Locus Array robot, Locus's new Robots-to-Goods platform: a fully autonomous fulfillment robot that drives to inventory and picks, puts away, and replenishes on its own.

    A machine like that is a lot of software working in concert, and my work runs through all of it, wherever the robot needs it that week. Beyond that I can't say much: most of what makes Array tick stays in the building.
    C++ · Python · ROS 2

  2. KUKA

    Senior Robotics Software Engineer

    Developed core robot OS modules for motion and external control, and designed external control interfaces focused on ease of use, comprehensive functionality, and scalable deployment. Co-developed an inverse kinematics and motion library built on saturation-in-the-nullspace (SNS) algorithms.

    Flagship

    An external jogging interface that pairs a 3D space mouse with the SNS solver: twist input becomes end-effector velocity through velocity IK, integrated into joint position commands streamed over ROS 2 control and the RTC driver. The solver enforces torque and acceleration limits internally, so jogging stays smooth even on high-payload arms.

    Constraint modes lock individual linear or rotational axes, and a relaxed-axis mode frees a chosen DOF. Relax tool RY, for example, and the solver uses the resulting nullspace to pass cleanly through singularities and joint limits.

    C++ · ROS 2 · SNS IK · RTC

  3. Kawasaki Robotics

    Robotics Software Engineer

    Built applications on Kawasaki Real-Time Control (RTC) and the Robot Network API, and consulted for universities, startups, and enterprises adopting RTC.

    Shipped internal tooling in C++, Python, and C#: automated robot configuration, purchase-order tracking, data logging and visualization, QA test suites, and a robot programming IDE. Also built 2D/3D vision demo systems.

    Flagship

    A live body-tracking follow/teach application: Azure Kinect skeleton tracking drives the arm to mirror an operator's movements in real time, recording positions and motions the way a teach pendant would. Built on RTC and ROS with MoveIt and the Azure Kinect ROS driver.

    C++ · Python · C# · ROS · MoveIt

03 / Projects

Projects

04 / Skills

Skills

Languages

  • C
  • C++
  • Python
  • C#
  • Rust
  • MATLAB

Robotics

  • ROS
  • ROS 2
  • Motion Planning
  • Controls
  • Kinematics
  • Computer Vision
  • Machine Learning

Computer Engineering

  • Real-Time OS
  • Linux
  • Computer Architecture
  • Signal Processing
  • Networking
  • Docker
05 / Contact

Contact

The professional record is on LinkedIn; the code is on GitHub.